The camera dips 10 to 15 percent of the frame height downward and drifts very
slightly backward, then holds almost still for 0.3 seconds with only a faint
side-to-side weight shift. The regular walking bob stops during this hold.
The camera accelerates upward fast, rising while pushing slightly forward, with
two or three frames of motion blur at the moment of departure. The horizon tips
a few degrees. Do not describe legs or a body.
For roughly 0.3 seconds the jolting step rhythm COMPLETELY STOPS. The camera
glides smoothly with no bounce at all, the surface below falling away. This
absence of bounce is what tells the viewer the animal has left the ground.
A hard impact: the camera drops sharply, rebounds slightly, the horizon rolls
20 to 30 degrees, one or two frames smear, and it settles within 0.3 seconds.
The regular two-per-second step rhythm then RESUMES.
Camera is a collar-mounted action cam on a cat, 15 to 20cm above whatever
surface it stands on. Ultra-wide 110-degree lens with mild barrel distortion.
Deep focus — everything from the near surface to the far end stays sharp; the
foreground blur of paws and whiskers comes from being too close to focus, not
from shallow depth of field. Translucent white whiskers arc in from the left
edge and the top-left corner, individually visible but soft, never on the right
side. Surfaces keep fine micro-texture with no smearing, no streaking and no
brushed look. Shadows lifted, no crushed blacks. Raw handheld animal-cam texture.
通用禁令(每段都帶)
Do not show the cat's nose, muzzle, nostrils, ears, tail or body. Only paws and
whiskers. Do not render a whole animal anywhere in frame, including reflections.
No long smears, no sustained motion blur, no melting geometry, no floating or
weightless drifting.
12 個動作條目
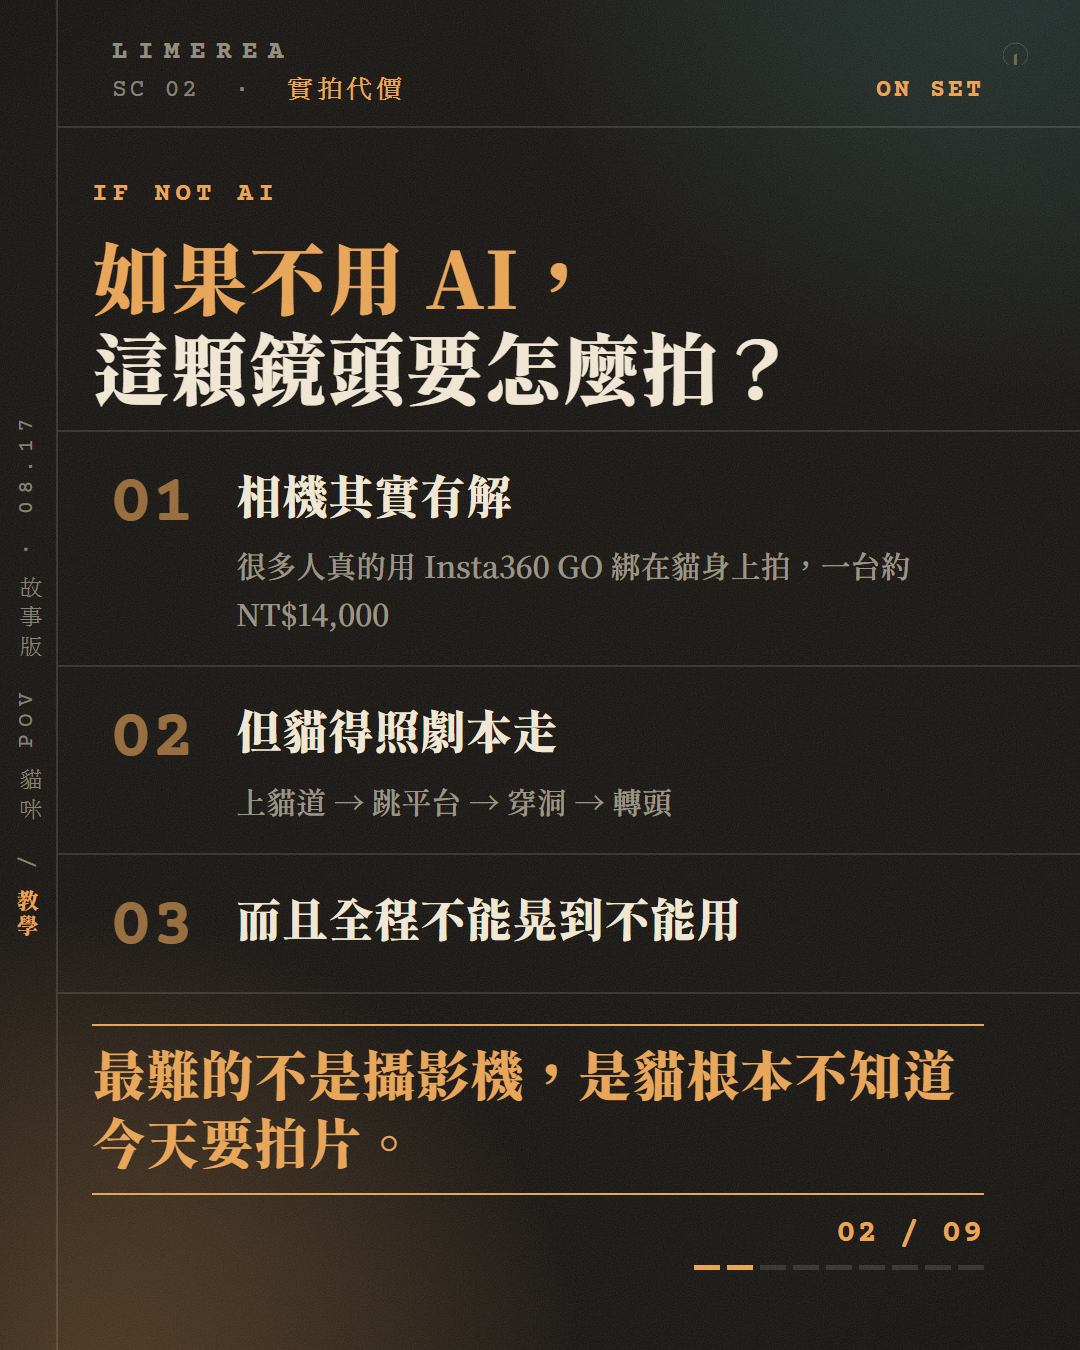
01蹲低準備GATHER
視角下沉 10–15%、微退、停 0.3 秒,步伐晃動停止=重心壓低的訊號。
The camera dips 10 to 15 percent of the frame height downward and drifts very
slightly backward, then holds almost still for 0.3 seconds with only a faint
side-to-side weight shift. The regular walking bob stops during this hold.
02起跳LAUNCH
快速上升+前推、離地瞬間兩三格動態模糊、地平線微傾。不寫腿、不寫身體。
The camera accelerates upward fast, rising while pushing slightly forward, with
two or three frames of motion blur at the moment of departure. The horizon tips
a few degrees. Do not describe legs or a body.
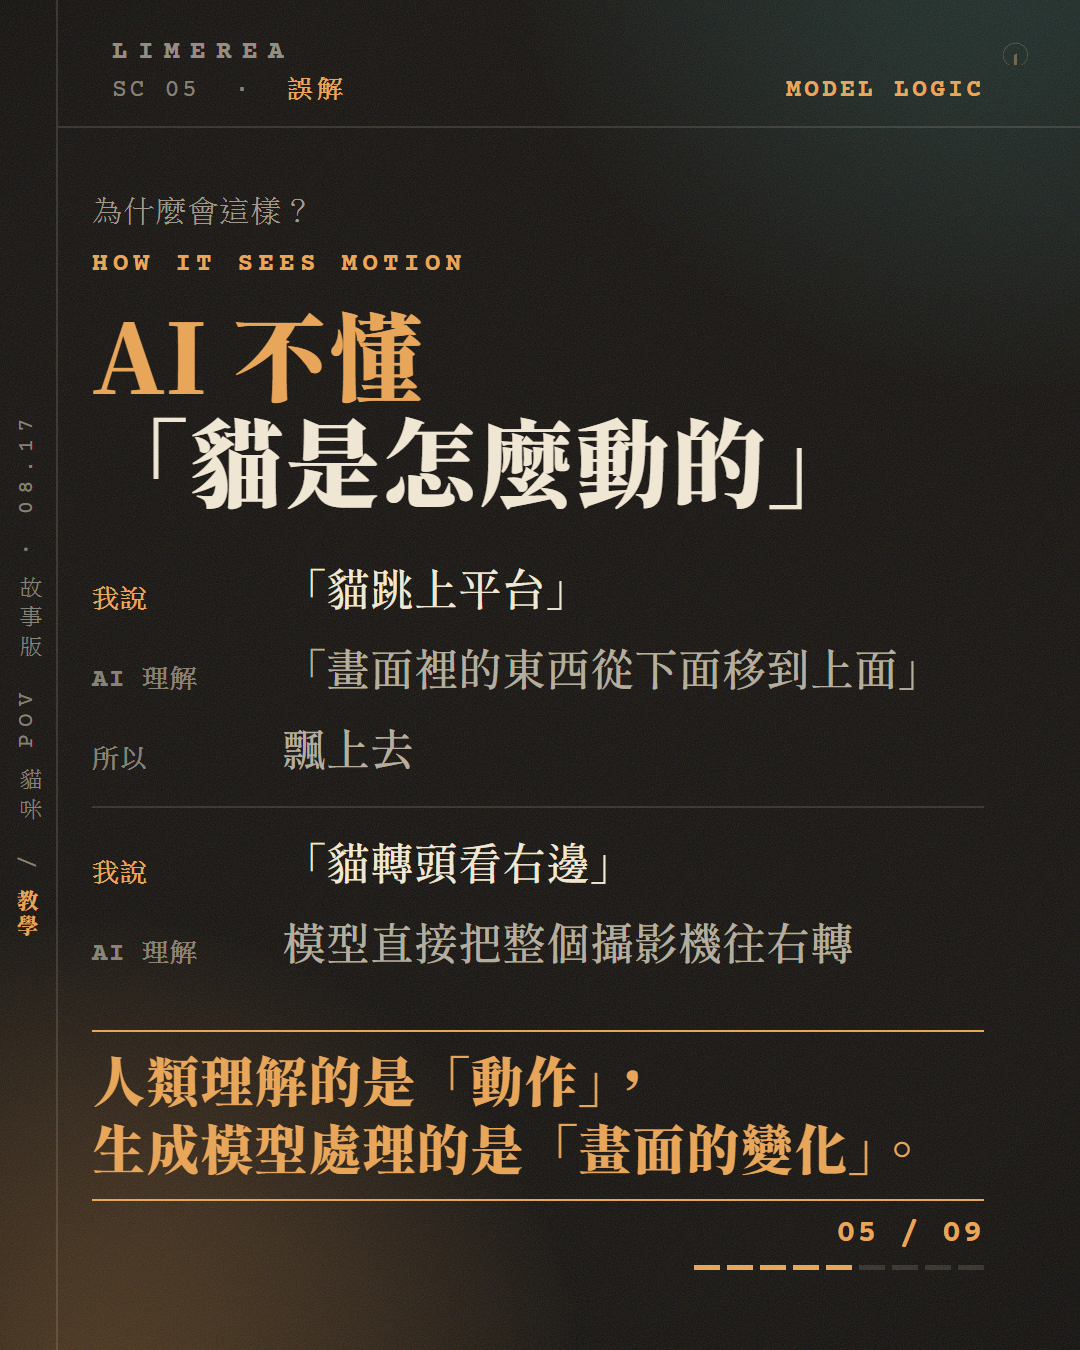
03騰空AIRBORNE · 最重要
0.3 秒內步伐頓挫完全停止、畫面變平滑漂移、下方表面遠離。「規律消失」=離地。
For roughly 0.3 seconds the jolting step rhythm COMPLETELY STOPS. The camera
glides smoothly with no bounce at all, the surface below falling away. This
absence of bounce is what tells the viewer the animal has left the ground.
04落地LANDING
硬衝擊:急沉 → 微彈 → 地平線滾 20–30° → 0.3 秒內穩住,步伐節奏恢復。
A hard impact: the camera drops sharply, rebounds slightly, the horizon rolls
20 to 30 degrees, one or two frames smear, and it settles within 0.3 seconds.
The regular two-per-second step rhythm then RESUMES.
05行走WALK
每秒兩步的頓挫感,每步起落 5–8% 畫面高,地平線左右搖 8° 內。絕不能是平滑滑行。
Jolting gait, two steps per second, each step dropping and lifting the camera by
5 to 8 percent of the frame height with a distinct jolt on landing, never a
smooth glide. Horizon rocks left and right within 8 degrees.
06停下觀察STOP & LOOK
幾乎完全鎖定,只剩 1–2% 畫面高的呼吸起伏。沒有步伐、沒有漂移。
The camera locks almost completely still, moving only with slow breathing at
about 1 to 2 percent of frame height. No steps, no drift.
07甩頭WHIP TURN
0.3 秒一記甩轉:硬起硬停、不加緩入緩出,轉動期間全畫面方向性拖影。
One sudden 0.3-second whip-turn: hard start, hard stop, no easing in or out,
heavy directional smear across the whole frame during the turn.
08攀爬上洞/撐上高處HAUL UP
兩段式上升:第一撐 → 重心轉移的停頓 → 第二撐過緣。一次滑順上升=電梯,不是貓。
The rise happens in TWO STAGES, not one smooth lift: a first lurch upward, a
brief hesitation as the weight transfers, then a second lurch that clears the
edge. The rim of the opening sweeps DOWNWARD past all four frame edges as the
camera rises past it.
09鑽過洞口SQUEEZE THROUGH
洞壁向畫面四邊外掃、進洞曝光下降、出洞回升,鬍鬚擦過洞緣。
The camera pushes forward while the walls of the opening sweep outward past the
frame edges. Exposure dips as it enters and recovers on the far side. Whiskers
bend and drag against the rim.
10往下跳DROP DOWN
加速下墜、地面迅速放大、墜落中步伐節奏停止,然後一記硬衝擊、0.4 秒內穩住。
The camera falls with acceleration, the ground below rushing up and growing
rapidly. The step rhythm stops during the fall. Then a hard impact: sharp
compression, a roll of 20 to 30 degrees, one or two smeared frames, settling
within 0.4 seconds. Brighter as it descends toward the lit floor.
11低頭看腳邊GLANCE DOWN
下傾不超過 40°、約 0.5 秒,近處表面與前掌充滿畫面下緣,然後回正。
The camera tilts down no more than 40 degrees for about 0.5 seconds, the near
surface and the viewer's own front paws filling the lower frame, then lifts
back to level.
12抬頭看上方LOOK UP
上仰不超過 40°、0.4 秒到位停住。仰過頭讓近處表面離開畫面下緣,就變腳架鏡頭,不是 POV。
The camera tilts up no more than 40 degrees over 0.4 seconds and holds, the
target above centred in the upper half of frame. Never tilt so far that the
near surface leaves the bottom of frame — that reads as a tripod shot, not a POV.
0.0-0.5s: [walk] toward the light-oak column at the end of the TV wall.
0.5-0.8s: [look up] at the stack of small rounded ledges in the alcove above.
0.8-1.1s: [gather].
1.1-1.3s: [launch].
1.3-1.6s: [airborne].
1.6-1.9s: [landing] onto the first ledge.
1.9-4.0s: [stop & look] from on top of the first ledge, the next ledge visible
          above and to the side. The cat stays on this ledge; it does not jump
          again and does not return to the floor.